- Smart City/Mobility Business HOME
- Search by use case
-
Search by product/service

- event·
seminar -
Case studies and columns
- Inquiry
What is point cloud data?
In recent years, the use of point cloud data has been attracting attention.
Point cloud data is data represented as a collection of points that have coordinate data. Until now, 3D representation methods have included wireframes, surfaces, solids, and meshes. While each of these is commonly used in 3D CAD and CAE, point cloud data has gained attention due to advancements in sensors. For example, LiDAR sensors used in autonomous driving can acquire point cloud data for a 360° surrounding area with a radius of 100m or more at 10 to 20 frames per second. This data is used for spatial recognition, to detect and identify objects, to avoid obstacles, and to use as an environmental map for self-localization, path generation, and tracking. It is no exaggeration to say that the mechanisms of early autonomous driving were made possible by these sensors.
While point cloud data can also be acquired using other sensors such as ToF cameras and stereo cameras, LiDAR is far superior in terms of accuracy and measurement range.
Applications of point cloud data extend beyond autonomous driving.
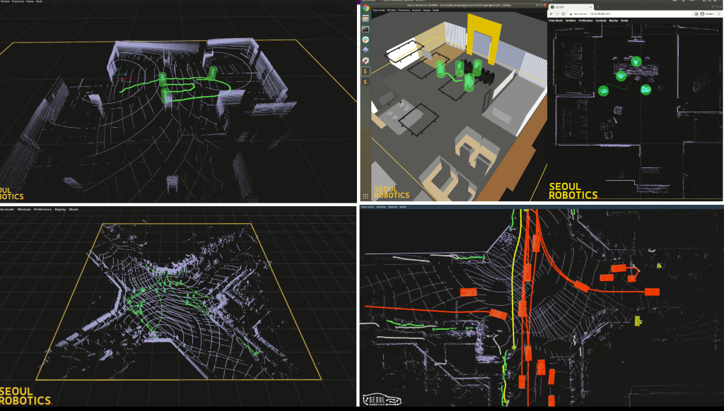
The use of point cloud data is being applied not only to autonomous driving as mentioned above, but also to monitoring people and vehicles, and its application in various locations such as pedestrian flow analysis and intersection monitoring is being considered. Our company also provides solutions to the needs and challenges of companies and local governments through our connections with LiDAR manufacturers and Perception suppliers around the world.
Ouster BlueCity
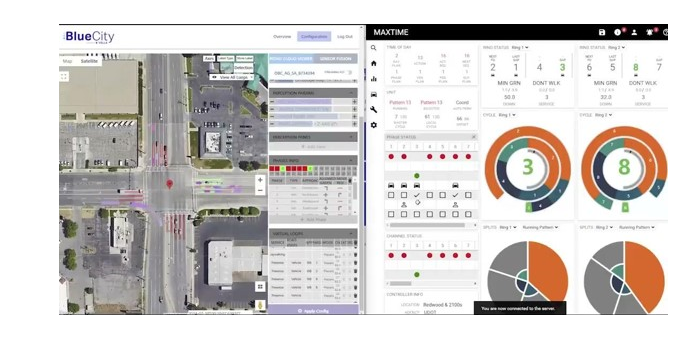
Ouster, a US-based LiDAR manufacturer, offers a tool called "BlueCity" that utilizes its wide-range rotating LiDAR to provide optimal recognition and also includes traffic environment analysis capabilities.
With a proven track record of implementation in the United States and other countries, the system includes features such as recording traffic incidents, displaying risk levels using heat maps, and switching traffic signals according to traffic volume.
Vueron Copilot
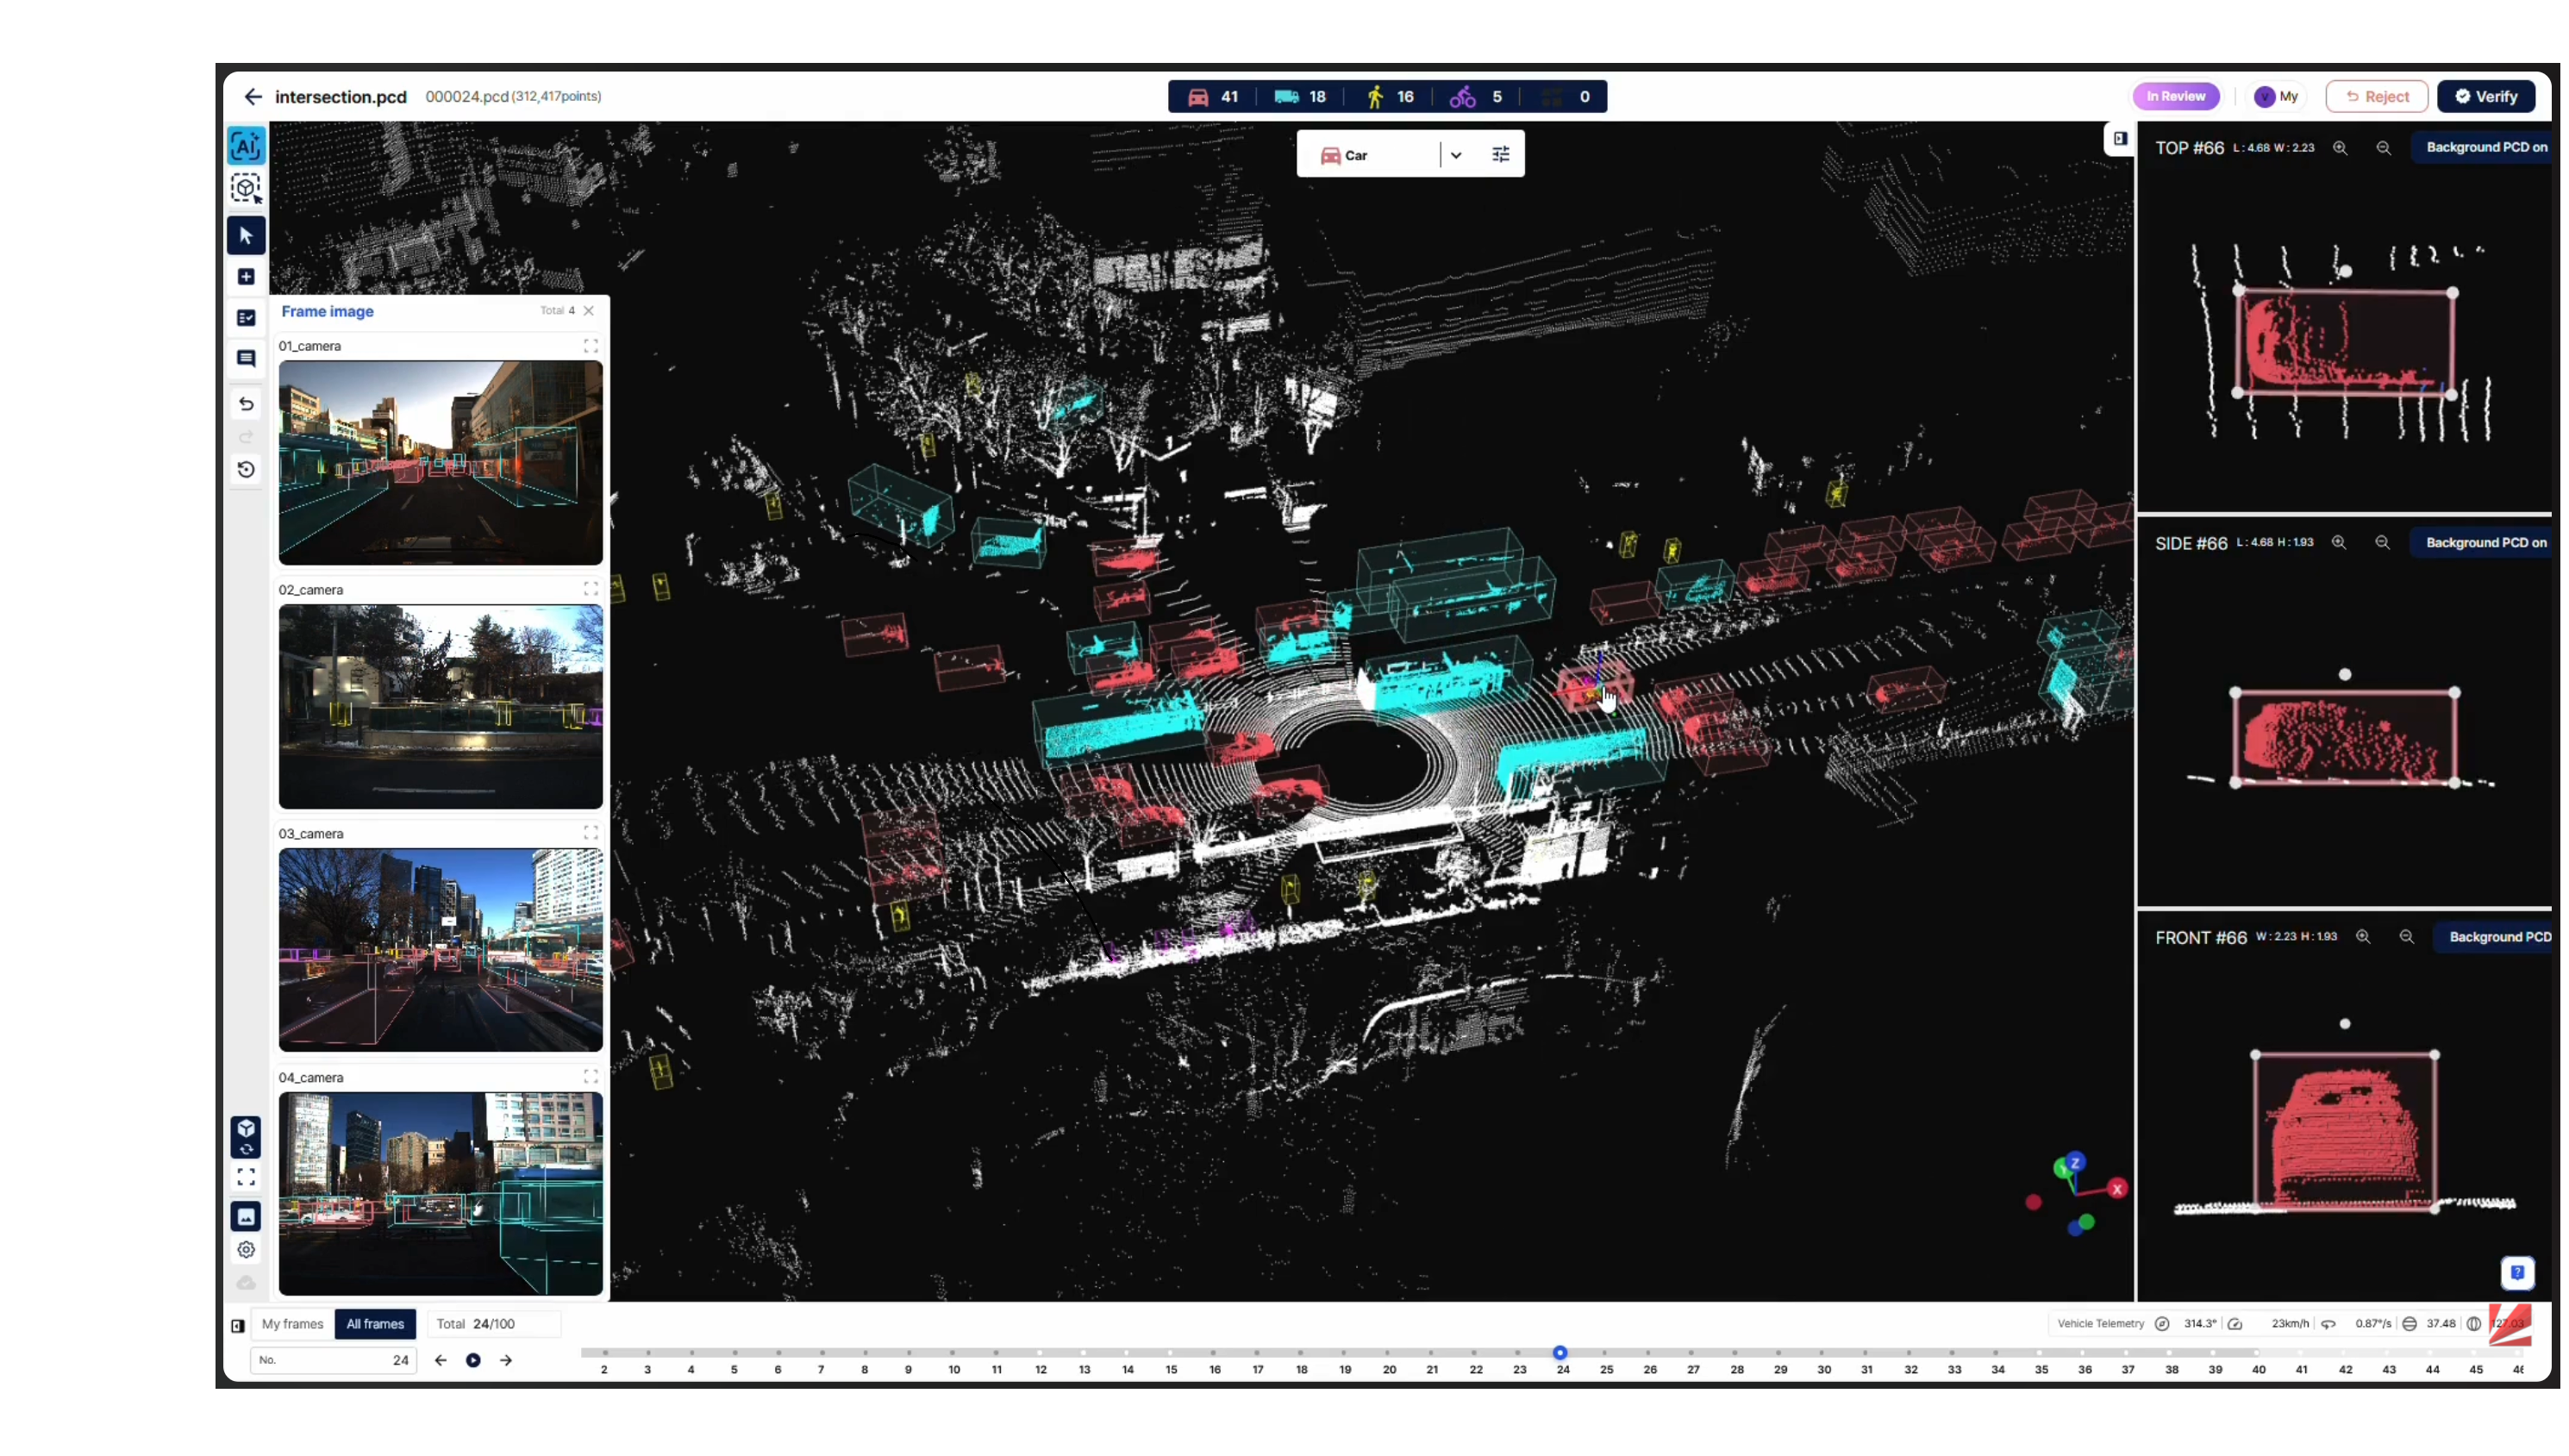
Vueron, a South Korean startup, was the first company in South Korea and the United States to obtain permission for autonomous driving using only a single LiDAR sensor, and has a strong track record in validating technology in real-world scenarios. Their Perception technology is being used not only in automobiles but also in infrastructure.
Their solutions are not limited by the type of LiDAR used, and they can provide the optimal combination of solutions to suit your desired cost, application, and installation environment.
- LiDAR technology is transforming various infrastructure systems: Parking lot management - the latest solutions for improved efficiency and safety.
- [Seiwa Electric] LiDAR Intrusion Detection Demonstration Experiment Report - Part 1
- Methods and construction of intrusion detection systems that detect the intrusion of people or moving objects.
The use of point cloud data is accelerating in the construction and infrastructure sectors.
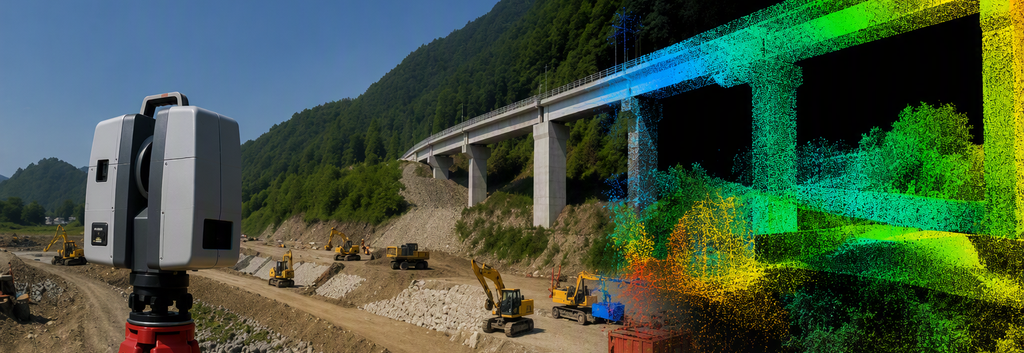
With the recent advancements in digital technology, the use of point cloud data is rapidly expanding, particularly in the construction and infrastructure sectors. In Japan, in particular, the Ministry of Land, Infrastructure, Transport and Tourism's "i-Construction" and "BIM/CIM" initiatives are driving the transformation of business processes based on three-dimensional data, and point cloud data is positioned as a fundamental technology for this transformation.
In the construction sector, surveying and progress management using point cloud data acquired by drones and laser scanners are becoming commonplace. Compared to traditional manual surveying, this allows for the acquisition of high-precision data over a wide area in a short time, significantly contributing to improved productivity and safety. Furthermore, the use of "Scan-to-BIM," which converts point cloud data into three-dimensional models (BIM/CIM), makes it easier to verify the consistency between design and construction and visualize construction progress, leading to reduced rework and improved quality.
Furthermore, its use is also progressing in the field of maintenance and management. By combining point cloud data with ledger information for infrastructure such as bridges, tunnels, and road appurtenances, it is possible to understand the deterioration status and improve repair planning. In fact, trials of a system that integrates point cloud data and management ledgers for road facilities have shown that it is possible to understand the situation and measure dimensions on a three-dimensional view, and that this has led to increased efficiency in maintenance and management.
Point cloud data is also important in the field of disaster prevention. During disasters, drones and other means are used to quickly acquire three-dimensional terrain data, which is then used to assess the extent of damage and formulate recovery plans. Furthermore, this data is integrated with other observational data and shared among relevant organizations through information sharing platforms (such as SIP4D), contributing to the improvement of wide-area disaster response capabilities.
Challenges in utilizing point cloud data
As mentioned above, while the use of point clouds is advancing, challenges remain. Point cloud data is large and difficult to handle, making the development of a data management and sharing system (CDE: Common Data Environment) essential. Furthermore, generating meaningful models from point clouds requires specialized knowledge and software, and a shortage of skilled personnel is also a challenge. In addition, technical difficulties have been pointed out regarding the alignment of point clouds with design models (BIM) due to data characteristics such as noise and missing data.
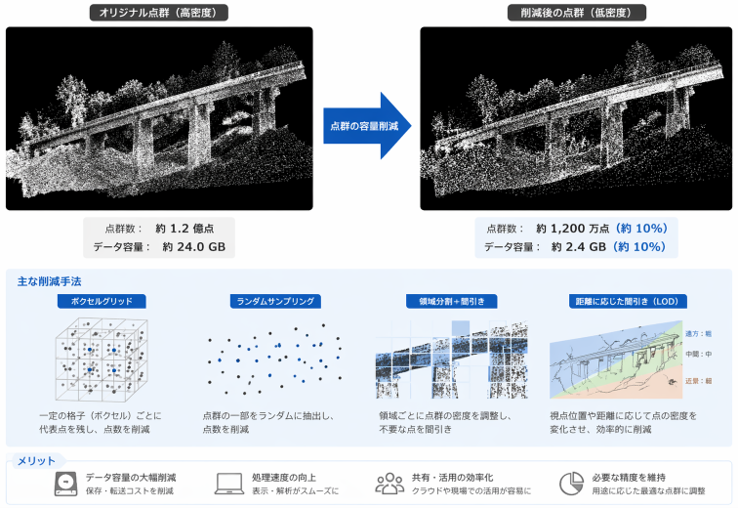
AiS-GNG is an algorithm that solves the challenges of point cloud data capacity and modeling.
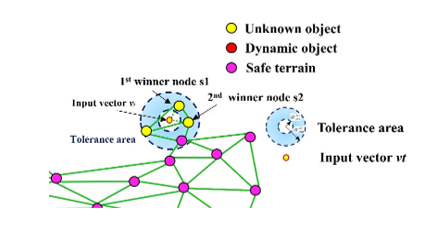
AiS-GNG (Add-if-Silent Rule-Based Growing Neural Gas), proposed by Shoji Fuzzy Robotics Laboratory, is effective in addressing the aforementioned challenges and is an intelligent algorithm for unknown environment recognition using 3D point cloud data. This method extends GNG (Growing Neural Gas), an unsupervised learning type neural network, and aims to enable robots to grasp unfamiliar objects and environments in real time.
Conventional GNGs can learn topological structures (connections of shapes) from point cloud data, but they have the challenge of not being able to adequately represent distant objects or regions with low data density. In response to this, AiS-GNG introduces a rule called "Add-if-Silent," which adds valid input data directly as nodes, enabling the generation of high-density structures even from sparse point clouds.
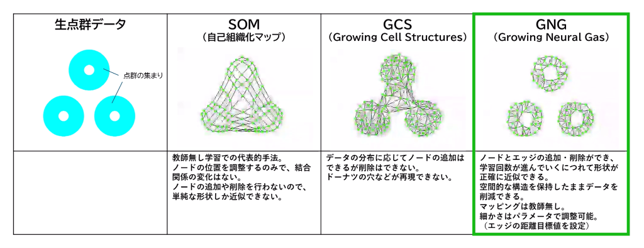
Recognizing unknown environments in real time
This feature allows for flexible learning of the shape and structure of unknown objects using only point clouds acquired by cameras or LiDAR, resulting in robust environmental recognition that is independent of lighting conditions and prior training. Furthermore, for extensions to dynamic environments, methods have been proposed to distinguish between static and dynamic objects using the amount of node movement, advancing the ability to handle situations closer to the real world.
In other words, it's a very effective method for generating meaningful models from point clouds.
At the Shoji Fuzzy Robotics Laboratory, we have prepared a web browser-based GUI to make these functions more intuitive to use. Using this, you can extract pre-identified objects such as moving objects, people, and cars from a space represented as a mesh by nodes and edges processed by AiS-GNG, and display them in a sub-window. In addition, point cloud clusters extracted by AiS-GNG clustering can also be output, allowing for various displays of extracted objects, such as nodes, edges, and point clouds. Traditionally, transmitting point clouds obtained from LiDAR directly over data buses and networks presented bandwidth problems, but by sending only the point clouds of objects of interest, such as moving objects, a reduction in communication capacity can be expected.
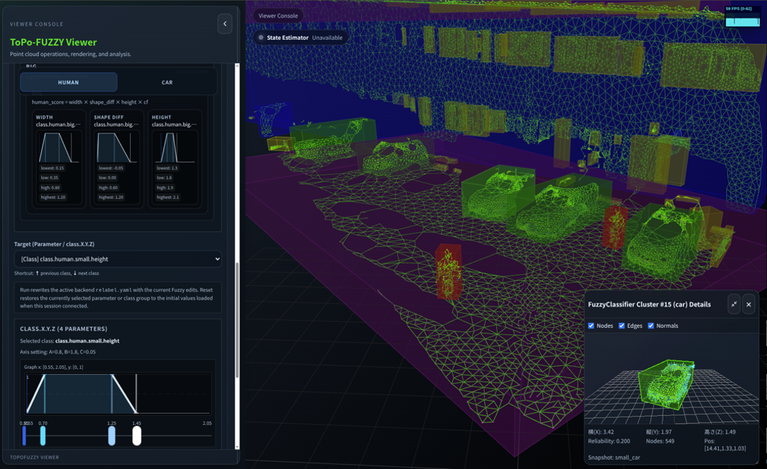
Smart data reduction by preserving important objects.
Furthermore, by reducing the volume of point cloud data from background elements other than the object (such as walls and floors), or by extracting only the point cloud data of the object, it becomes possible to reduce the volume, which was a challenge mentioned above.
Conventional voxel grid filters reduce the volume of the point cloud by thinning it out to be uniform in space, but this also reduces the volume of the point cloud of the object of interest. However, AiS-GNG's downsampling filter can reduce the volume of the point cloud of walls, floors, etc., without reducing the volume of the point cloud of moving objects of interest.
Furthermore, using their provided GUI, you can perform real-time optimization of the optimal downsampling parameters with two sliders: one for how much to reduce the overall point cloud size, and another for reducing the size uniformly or focusing on the background.
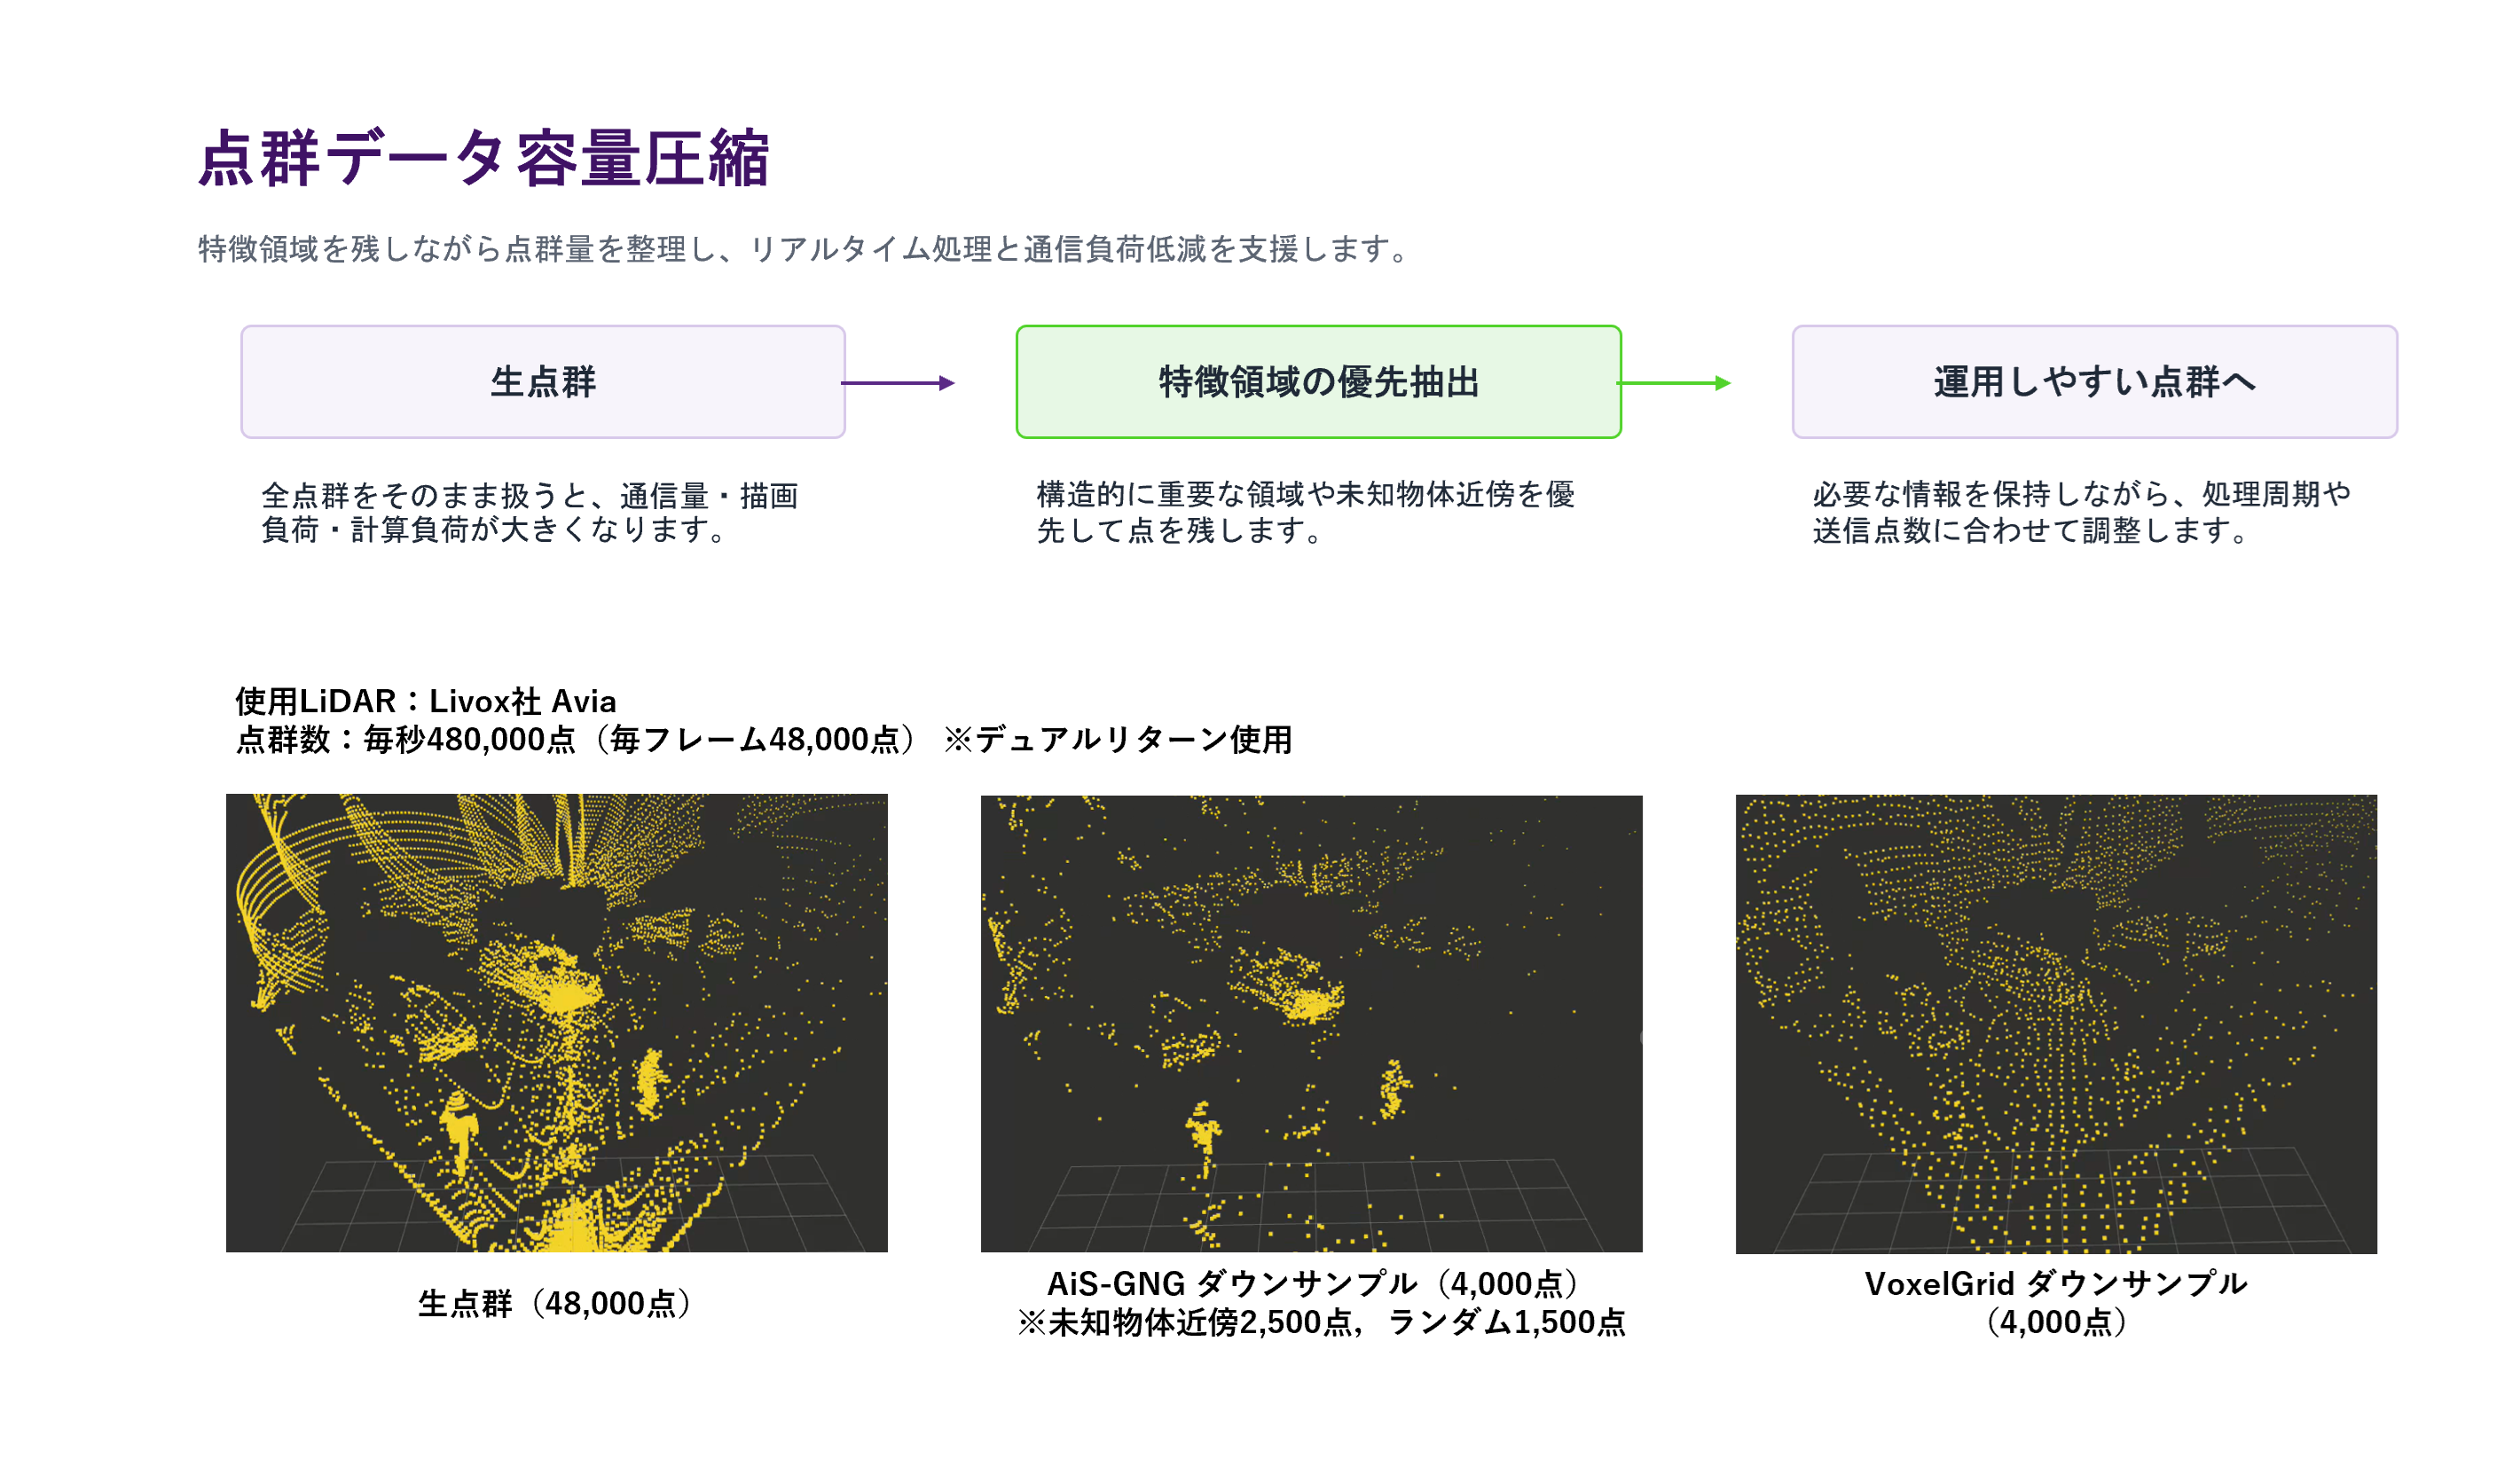
Expected to be a fundamental technology supporting the use of point clouds.
Thus, AiS-GNG is expected to contribute to the advancement of perceptual systems in the autonomous behavior of mobile robots and service robots as a foundational technology for understanding the environment based on point clouds.