- Semiconductor BusinessHOME
- Products and Services of Macnica,Inc.
-
technical information

-
Events and Seminars
- Handling Manufacturer
- Support
- Inquiry
- Click here to purchase products
- Semiconductor business e-mail magazine registration


 Narrow down by specifying conditions
現在2242件がヒットしています。check
This article explains practical considerations for manufacturing site managers and DX promotion leaders in deciding whether to implement Physical AI.
Three key elements to consider when implementing physical AI.
When implementing physical AI, it is crucial to clearly define the "target tasks," "data," and "exit points for verification" before beginning the robot selection process.
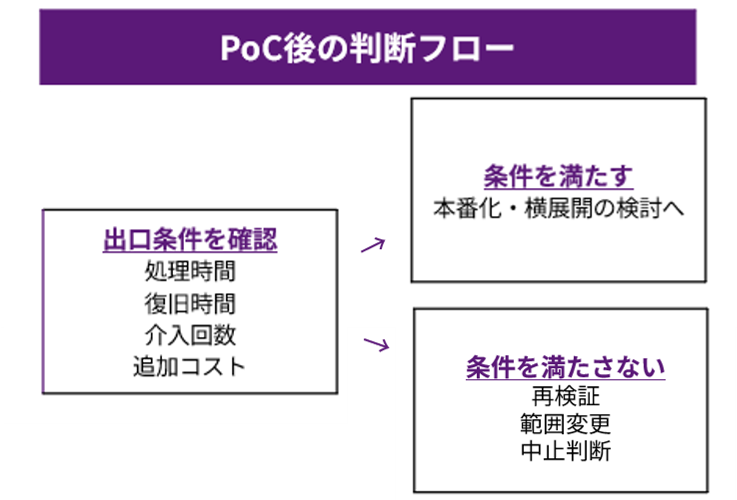
In this context, "exit points for verification" refer to the conditions used to determine whether to proceed with production deployment, conduct additional verification, or discontinue the project after the PoC (Proof of Concept) has been completed. Defining these conditions in advance prevents the PoC from ending as mere technical verification and makes it a more effective initiative that leads to a decision on implementation.
Introduction: The more hastily you select a robot, the more ambiguous the purpose of the Proof of Concept (PoC) becomes.
As the use of generative AI expands from the digital realm to the physical workplace, interest in "Physical AI," where robots and equipment perceive, judge, and act upon the real world, is growing. In particular, in manufacturing sites, in addition to addressing labor shortages and the transfer of skills, there is a growing interest in whether humanoid robots can replace tasks previously performed by humans.
On the other hand, in the initial stages of considering implementation, discussions tend to focus on implementation aspects such as "which robot should we choose?" and "which GPU should we adopt?". However, if the means are decided without a clear objective, even if the PoC itself is completed, it becomes unclear later on "what the PoC was for" and "what the verification was intended to determine," making it difficult to connect to investment decisions. To successfully implement Physical AI, it is important to clarify the objectives and success conditions of the PoC by organizing the target tasks, data to be used, evaluation criteria for verification results, and operating conditions in advance, before selecting a robot.
This article outlines four key considerations for managers and DX promotion leaders who are considering the automation of existing tasks using humanoid robots in manufacturing facilities. It also introduces the concept of the implementation platform and a pre-implementation checklist.
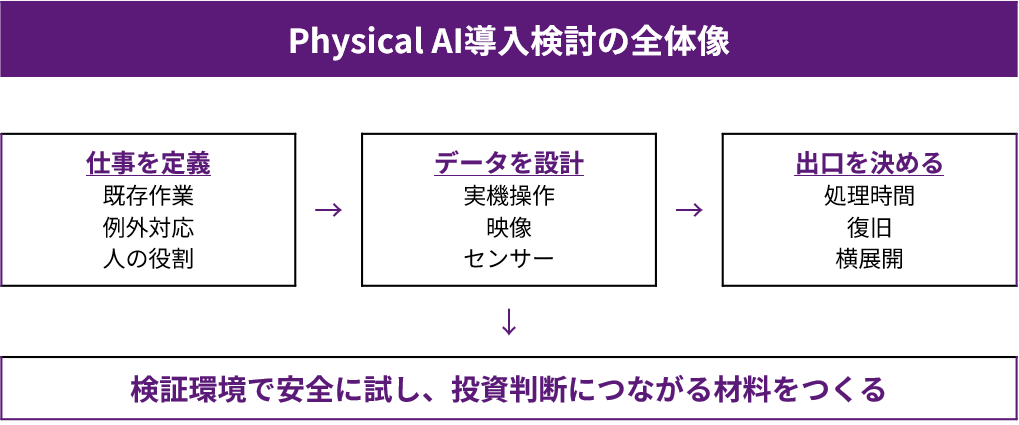
Point to consider 1: Define the target as "work" rather than "robots".
Simply stating "We want to introduce humanoid robots" is insufficient to define the scope of the evaluation. In manufacturing environments, tasks that humans perform naturally, such as picking up parts, setting them in jigs, transporting them before and after inspection, handing over tools and materials, and verifying work procedures, often involve numerous judgments and exception handling.
Therefore, it is crucial to first break down the work on-site into units such as "recognition," "judgment," "movement," "grasping," "placement," "verification," and "recording." Then, clearly define which processes will be entrusted to humanoid robots and which will be handled by humans.
Questions to confirm
What processes are included?
Whose burden, and what kind of burden, do you want to alleviate?
How will you handle exceptions, not just normal operations?
What criteria will be used to evaluate results, such as time, quality, safety, and utilization rate?
Point to consider 2: Decide how to collect data before creating an AI model.
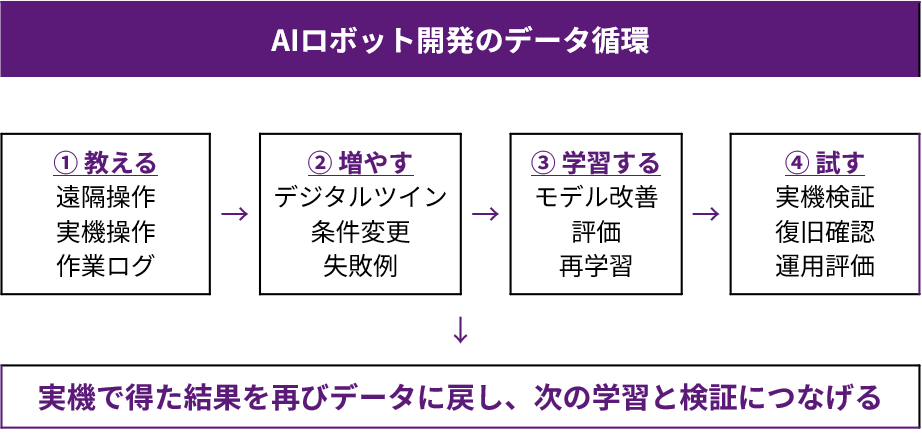
In Physical AI, site-specific objects, lighting, movement patterns, work variability, and sensor conditions all influence the results. Therefore, it's necessary to decide not only "which model to use," but also "what data to acquire, how often, who will acquire it, and how to feed it back into evaluation." Furthermore, if real-world data alone cannot sufficiently increase the number of conditions, it is effective to combine simulations and synthetic data to design a learning and evaluation cycle. The important thing is to operate the data not as a one-off PoC deliverable, but as an asset that supports continuous improvement. Organizing which data will be needed for the next learning and validation before starting the PoC is the shortest path to full-scale deployment.
Point to consider 3: Decide on the outcome of the PoC before starting.
The purpose of a Proof of Concept (PoC) is not simply to "confirm that it works." Its true purpose is to obtain information to decide whether to proceed with production deployment, re-evaluate under different conditions, or postpone the deployment altogether.To achieve this, agreeing on evaluation metrics, evaluators, necessary records, and next investment conditions at the start of the PoC makes it easier to connect technical verification to business decisions.
For example, in a proof-of-concept (PoC) where existing tasks are replaced by humanoid robots, it is important to pre-determine conditions such as the acceptable processing time compared to manual labor, how long it takes to recover in case of a stoppage, how often on-site workers will need to intervene, and how much additional equipment, training, and operational costs will be incurred when expanding to multiple lines.
The key is not to decide on the exit conditions after the verification. By establishing criteria before verification, such as "If this condition is met, we will proceed with the next investment," "If this condition is met, we will reconsider," or "If these constraints remain, we will postpone implementation," you can align the expectations of all stakeholders. This will transform the post-verification report from a collection of opinions into a basis for future decision-making.
Examples of exit conditions for a Proof of Concept (PoC)
- - Processing time must fall within a predetermined target range.
- - The ability to recover on-site in the event of a shutdown.
- - The number of human interventions remains within an acceptable range.
- - The cost required for relearning and resetting when the target object or working conditions are changed can be estimated.
- - The ability to explain the additional costs and operational structure required when expanding to multiple lines.
Point to consider 4: Create an environment where failure is safe before bringing it to the site.
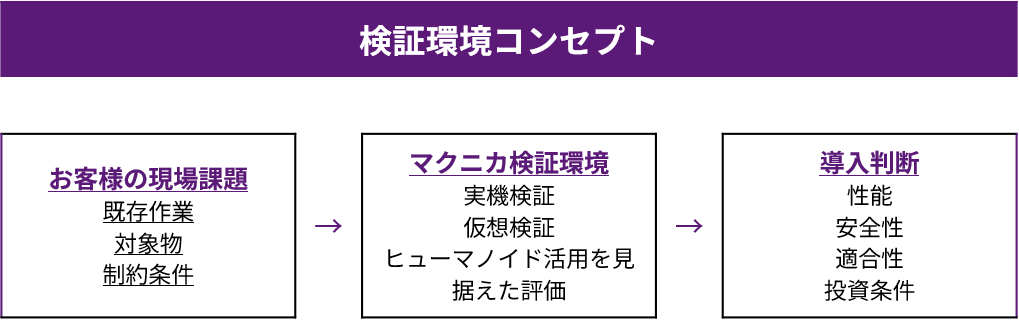
Bringing actual equipment directly to the production site presents numerous constraints simultaneously, including safety measures, stop-down adjustments, equipment interference, and information management. Therefore, a verification environment simulating on-site conditions is prepared to confirm not only operation but also accuracy, speed, stability, exception handling, safety, and recovery methods.
Simulation does not eliminate the need for actual hardware. It is a means to test dangerous conditions and numerous variations in a virtual environment, verify them on actual hardware, and then return the results to the learning and evaluation process. By assuming this back-and-forth between virtual and actual hardware verification,
This allows you to increase the speed of improvement while minimizing implementation risks.
Macnica 's verification environment
Before bringing the system to the site, we recreate the target work, sensor conditions, behavior in exceptional cases, and safety checks to concretize the PoC (Proof of Concept) image. The results obtained here are then used as material for on-site verification and investment decisions.
Macnica is developing a verification environment for Physical AI, and is working on real-world machine verification simulating manufacturing site operations, as well as concretizing verification themes with a view to the use of humanoid robots. We aim for this to be used as a place to confirm performance, safety, and suitability before implementation, and to make a plan for proof of concept (PoC) before preparing equipment in-house.
An implementation platform that connects learning, simulation, and actual hardware.
Physical AI requires the integration of a computing infrastructure for training and improving AI models, a simulation environment for verification in a virtual environment, and an edge infrastructure for inference and control in the field. Rather than considering training, virtual verification, and actual device implementation separately, it is important to design the system so that the results obtained from actual devices are fed back into the training and evaluation process.
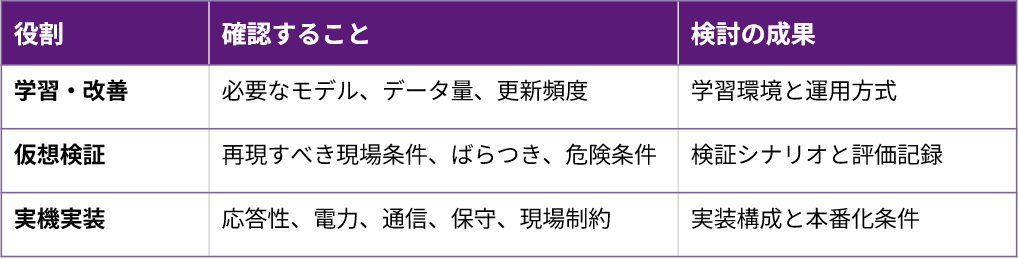
We will also consider product lines such as NVIDIA Omniverse™, NVIDIA Isaac Sim™, NVIDIA Isaac™ ROS, and NVIDIA Jetson™, organizing them according to their respective roles in learning, virtual verification, and actual device implementation.
Furthermore, if you want to first organize the specifications and technical elements and then get hands-on experience to understand the development environment and verification procedures, the AI robot development support package "ROBODEV" offered by Macnica and GDEP Advance is another option. ROBODEV is a solution that combines a development environment that allows for easy setup of NVIDIA Omniverse, NVIDIA Isaac Sim, NVIDIA Isaac ROS, etc., on a GPU workstation with verified operation, with hands-on support after implementation.
In robot development, it is crucial to define the verification conditions before starting to set up the environment. Specifically, this involves clarifying the target to be reproduced in the simulation, the sensors and data to be used, and the scope of use for ROS 2 or Isaac ROS.
In the hands-on sessions, after gaining an overall understanding through lectures, participants can progressively experience basic Isaac Sim operations, simple robot creation, dataset creation using Omniverse Replicator, integration with Isaac ROS, and AI model creation. By conducting verifications while actually interacting with the environment, it becomes easier to concretize the specifications, technical elements, and organizational structure necessary for your company's verification plan.
Summary: The first thing you should prepare is "the information needed for decision-making."
Physical AI is not about simply introducing a robot, but rather an initiative that circulates field data, AI models, and machines. That's why the first step isn't product selection, but defining the target tasks and success criteria. Next, a plan is created for data acquisition and virtual/real-world verification, and based on the results, the necessary computing infrastructure, simulation environment, and edge devices are selected.
Implementation Consideration Flow: From Business Definition to Investment Decision
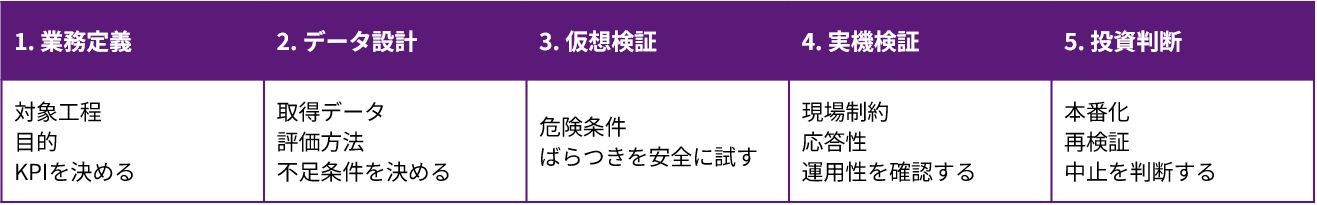
Pre-implementation checklist: Before considering the use of humanoid robots in your manufacturing environment
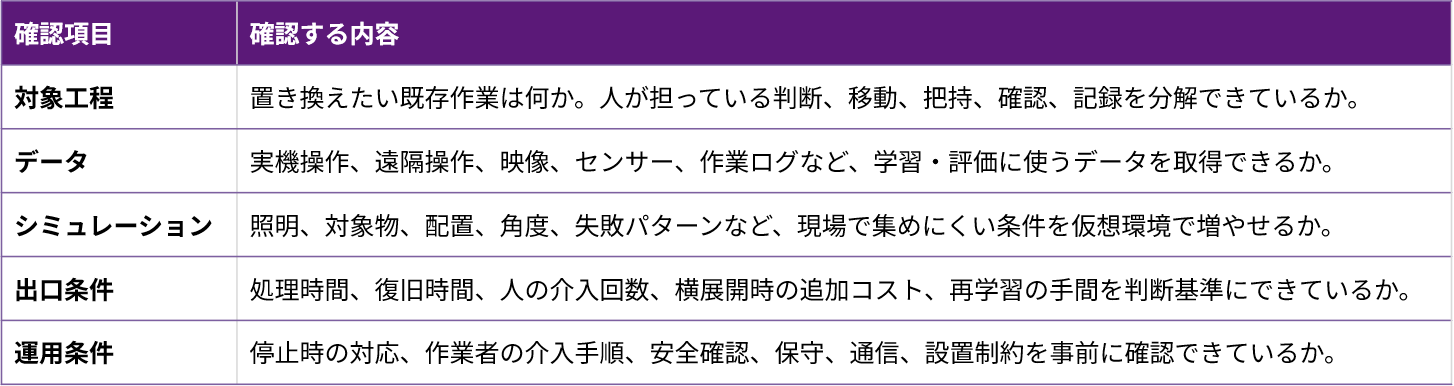
Timing of consultation: Organize the target process and verification plan before selecting a product.
If the target process, success conditions, data to be acquired, and verification methods are unclear, it is effective to consult before selecting a product. By clarifying the business definition and data design before deciding on the necessary computing resources and equipment configuration, it becomes easier to avoid rework and excessive configurations.
Macnica supports not only the selection of NVIDIA products, but also the planning and verification of pre-implementation processes, connecting sensors, data, simulation, edge implementation, and actual device verification. From the stage of considering the possibility of replacing existing tasks with humanoid robots in the manufacturing plant, you can consult with us on specifying target processes, verification themes, and evaluation metrics.
Furthermore, if you would like to try things out on a small scale while organizing the specifications and technical elements, we will support you through ROBODEV sales and hands-on training, from setting up the development environment to understanding NVIDIA Isaac-related technologies, utilizing the simulation environment, and initial verification of AI robot development.
Contact Us
When considering the use of Physical AI or humanoid robots in your own workplace, you can start with technical element verification, PoC consultation, and development environment setup support, depending on your application and stage of consideration. Please utilize the following support services according to your current stage of consideration.
◆ ROBODEV Hands-on:
By actually operating NVIDIA Isaac Sim, Isaac ROS, NVIDIA Omniverse, and other tools, you can deepen your understanding of the technical elements and development environments necessary for physical AI and AI robot development.
Click here for details
◆ Consultation regarding PoC:
We can advise you on how to conduct a Proof of Concept (PoC) with a view to full-scale implementation, including selecting target processes, designing data, and setting evaluation metrics.
Please contact us first using the inquiry form below.
Related terms
Product names and technical terms appearing in this article are explained on the following glossary page. Please refer to it as well.