- Semiconductor BusinessHOME
- Products and Services of Macnica,Inc.
-
technical information

-
Events and Seminars
- Handling Manufacturer
- Support
- Inquiry
- Click here to purchase products
- Semiconductor business e-mail magazine registration


 Narrow down by specifying conditions
現在2247件がヒットしています。check
The demo presented in Episode 4 demonstrates how to detect changes in activity using an accelerometer (IMU) built into a microcontroller board and how to handle this information with NVIDIA NemoClaw. The activity can be anything, such as human movement or vibrations from manufacturing equipment; there are no particular limitations, but it is assumed to be something that changes rapidly in a short period of time. Therefore, this demo assumes a use case where the AI agent must respond to changes in activity in real time, which is a major difference from the demos in Episodes 1-3.
System configuration
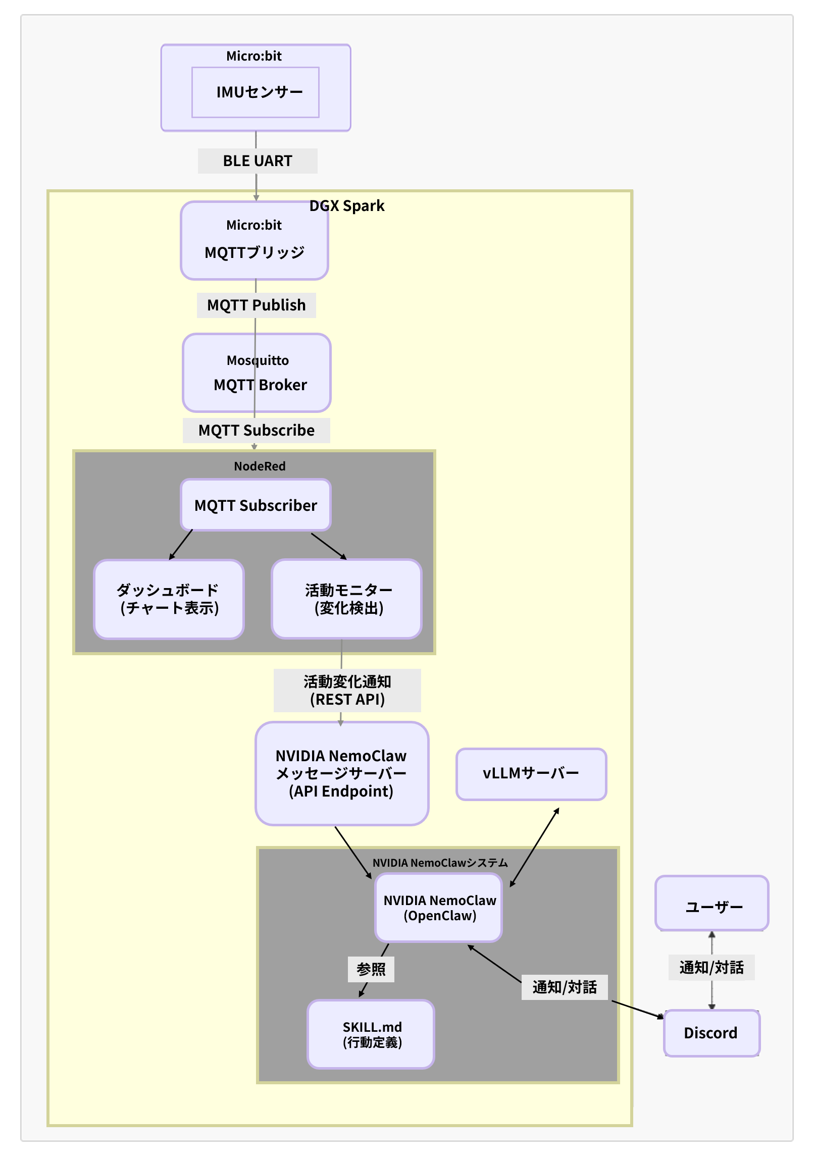
We used the IMU built into the micro:bit. Sensor data is sent from the micro:bit to the NVIDIA DGX Spark™ via BLE UART, and then converted to the MQTT protocol and published by the micro:bit MQTT bridge. The data is subscribed to within the Node-RED flow to detect changes in activity. A NemoClaw message server is set up to notify NemoClaw in real time of detected change events.
|
module |
role |
|
micro:bit (IMU) |
Source of sensor data |
|
micro:bit MQTT Bridge |
BLE UART → MQTT conversion |
|
Mosquitto |
MQTT Broker |
|
Node-RED |
Sensor data processing, activity change detection, and dashboard. |
|
NemoClaw Message Server |
API between Node-RED and NemoClaw |
|
vLLM server |
Running Local LLM |
|
NemoClaw |
Actions based on the central AI agent, SKILL.md. |
|
Discord |
User notification channels |
Real-time event notifications
Problems with event notifications (as of the time of writing this series)
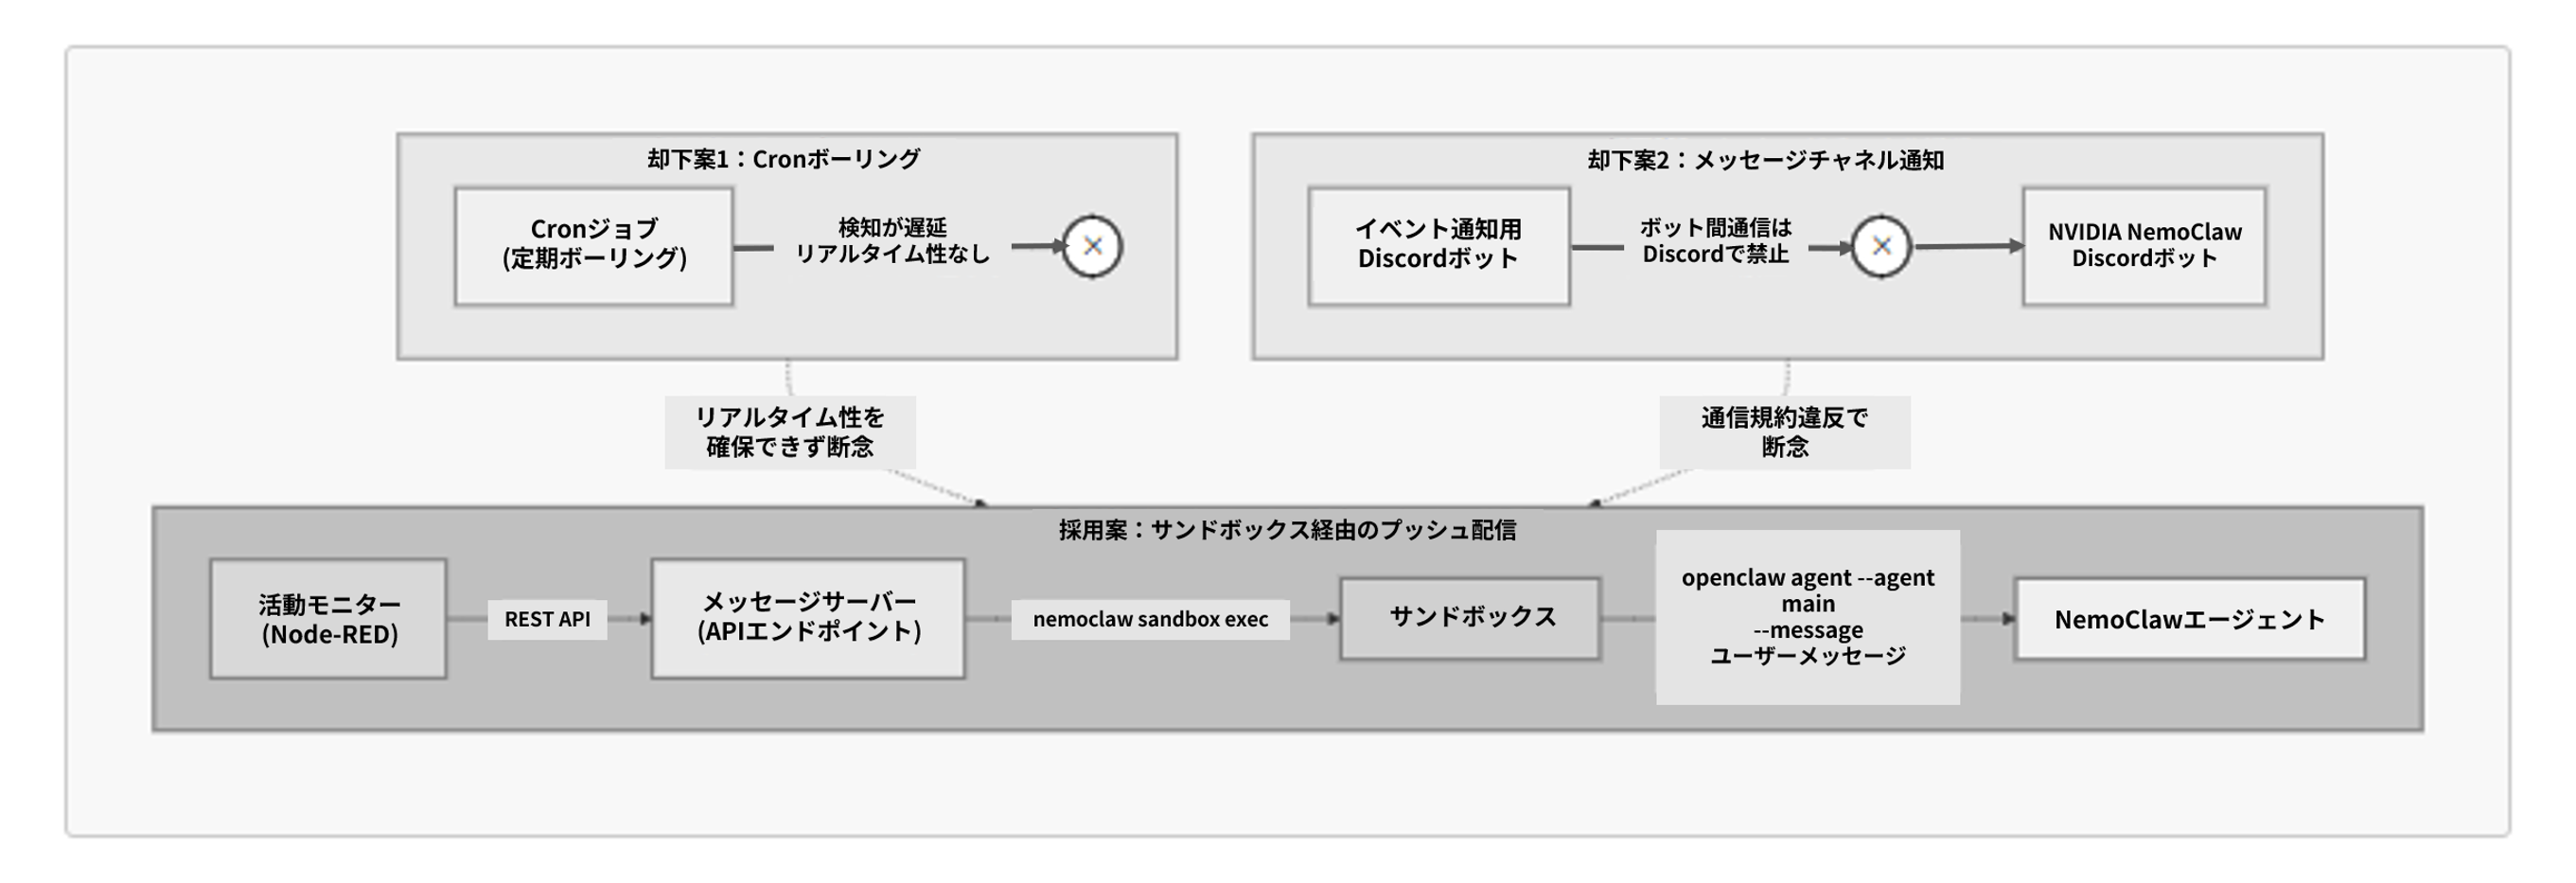
• Polling methods have limitations in terms of real-time performance.
NemoClaw The core OpenClaw So, as shown in the demo in the previous episode, Cron The job function is used to poll for external events at regular intervals. However, it is unsuitable for applications requiring real-time performance, such as anomaly detection, and therefore requires external programs to... NemoClaw A push notification system for events is needed.
・ Webface Unable to use the function
Originally OpenClaw of Webface There are ways to utilize the function, but as of the time of writing this series... NemoClaw Since it's unavailable to users, we need to consider alternative methods.
・ DiscordBot-to-bot communication using this method is not possible.
Discord From the message channel, such as the channel OpenClaw For messages entered, AI Because the agent can respond immediately, we initially considered notifying the event via a message channel. However, with this method, the party sending the event notification also... Discord It becomes a bot and already exists on the message recipient's end. Discord This would result in communication between bots. Discord It is prohibited there.
Event notification method adopted
There is a command called ` nemoclaw sandbox exec` that allows you to execute commands within the Box.
Using this feature, you can run `openclaw agent --agent main --message user message` within the Box to instantly deliver the message to the AI agent in NemoClaw.
This command will be executed from Node-RED running within a Docker container, so we will turn it into an API endpoint.
- Because the AI agent cannot determine the recipient of a reply to messages delivered using this method, you need to specify the channel ID of the Discord channel to which the reply should be sent using SKILL.
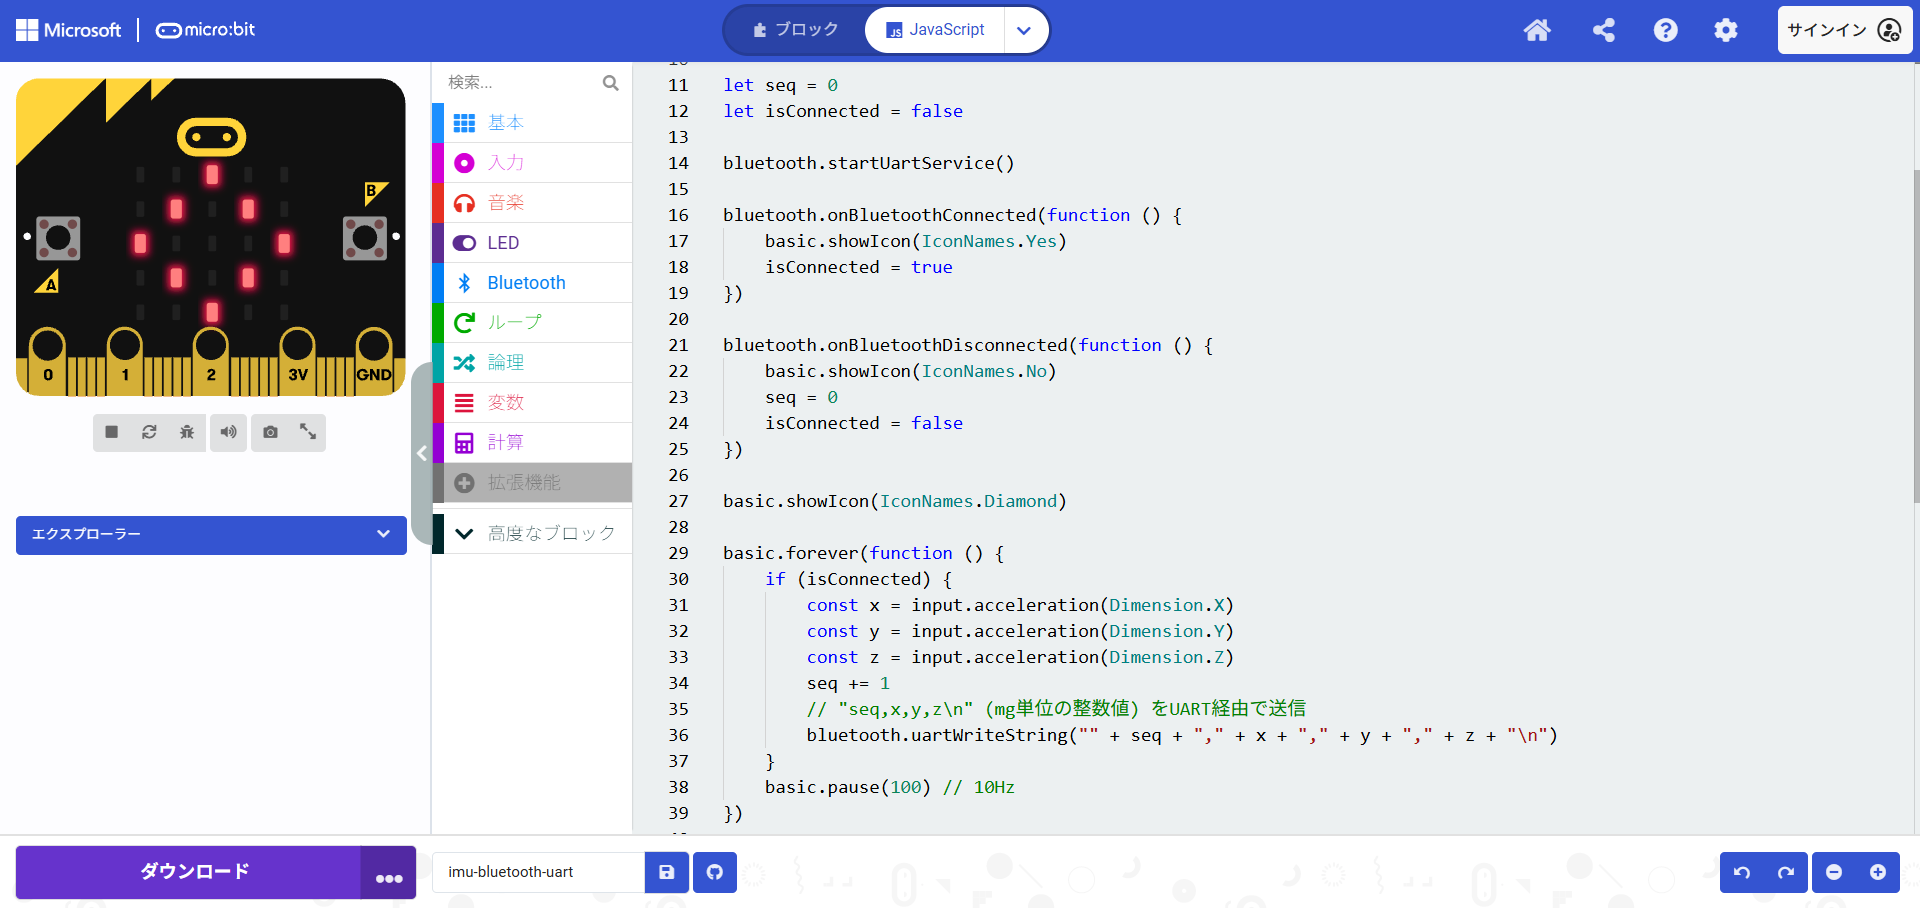
IMU data transmission
The following is the code to send IMU data via BLE UART.
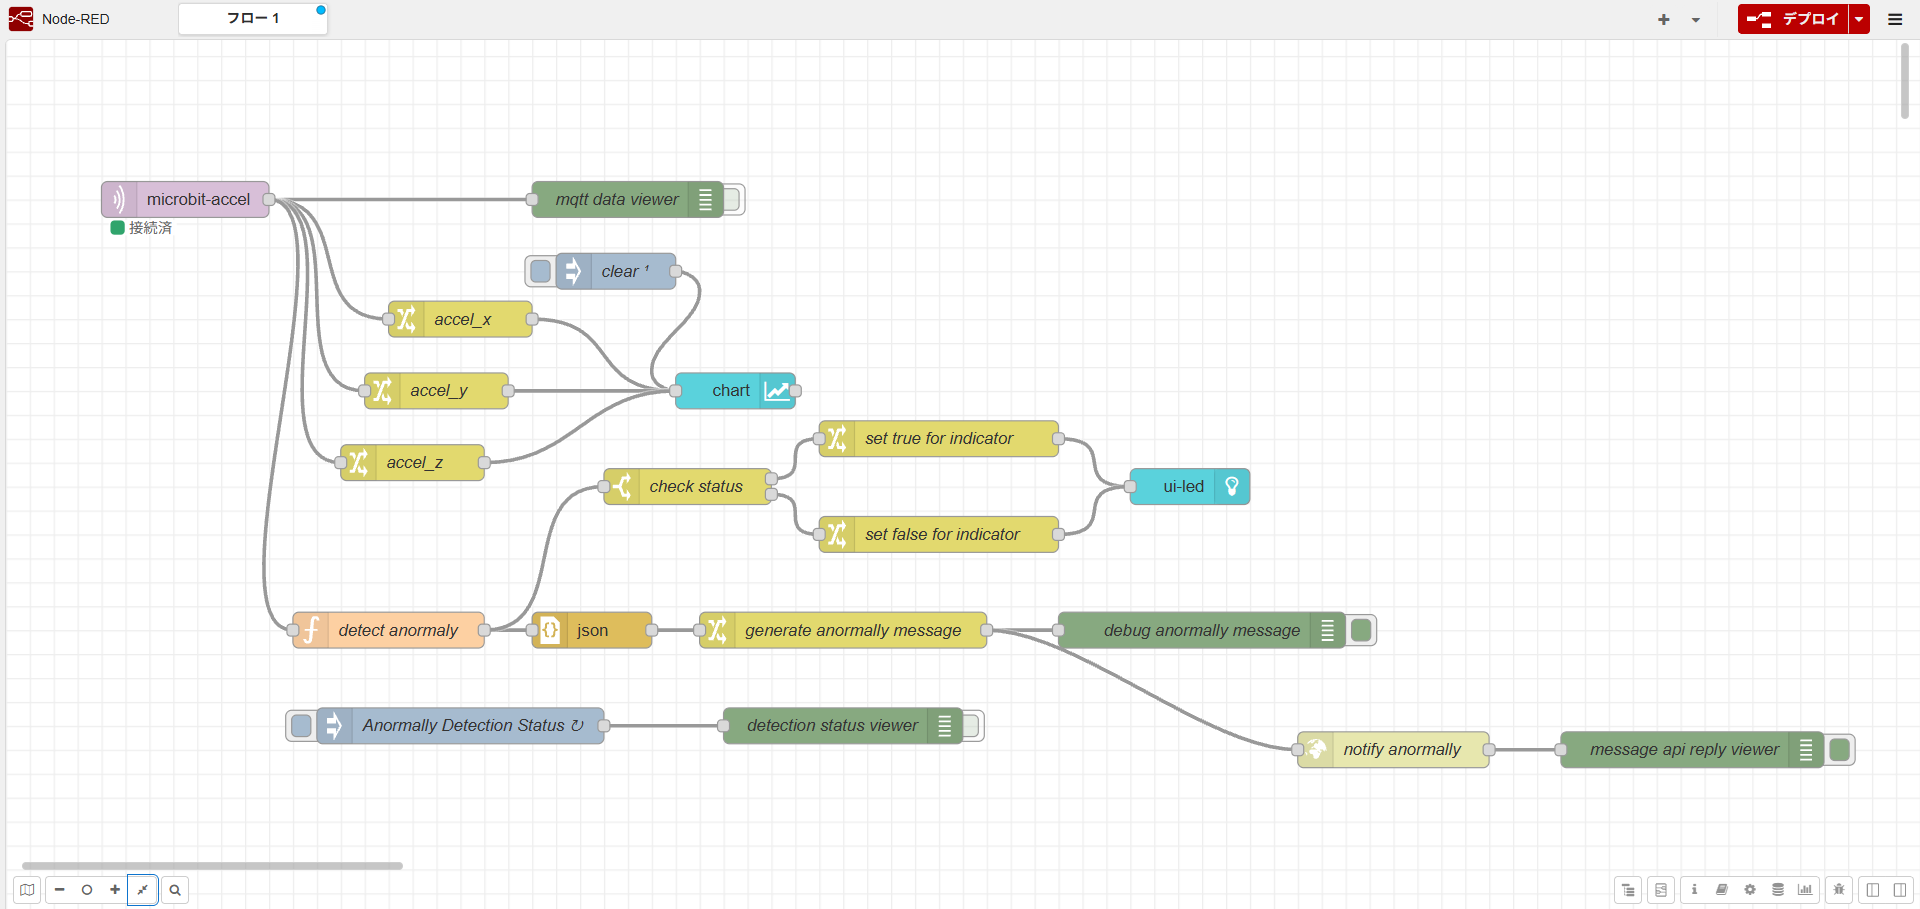
Node-RED flow
Node-RED The following features were implemented in the flow:
MQTT subscriber
• Dashboard (chart display)
• Activity monitoring (change detection)
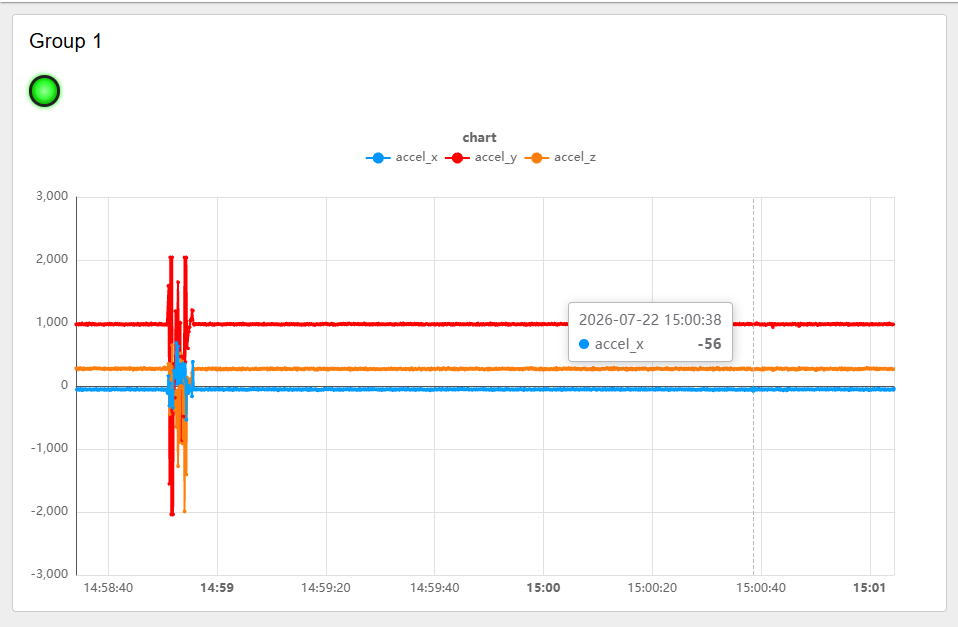
Dashboard
You can monitor IMU sensor values in real time on the dashboard.
Activity Monitor
The code to monitor activity and detect changes was implemented using Node-RED functions. From the perspective of ensuring real-time performance, it is better to leave the handling of detected change events to NemoClaw 's AI agent rather than placing this functionality within NemoClaw itself. The following is the function that monitors activity.
// ===== function ノード: 動作切り替わり検知 ===== // 入力 msg.payload: { accl_x, accl_y, accl_z, gyro_x, gyro_y, gyro_z } (1サンプル) // 出力: 切り替わりが起きた時だけ msg を送出 const WIN = env.get("AD_WINDOW"); // 窓サイズ(サンプル) const HOP = env.get("AD_HOP"); // 何サンプルごとに判定するか const MIN_HOLD = env.get("AD_MIN_HOLD"); // 状態確定に必要な連続回数 // しきい値(キャリブレーション値で上書き推奨) const TH_HIGH = flow.get("thHigh") ?? 200.0; const TH_LOW = flow.get("thLow") ?? 10.0; // --- リングバッファ取得 --- let buf = flow.get("imuBuffer") || []; const p = msg.payload; const accMag = Math.sqrt(p.accel.x * p.accel.x + p.accel.y * p.accel.y + p.accel.z * p.accel.z); buf.push({accMag}); if (buf.length > WIN) buf.shift(); // 古いものを捨てる flow.set("imuBuffer", buf); // --- HOPごと & 窓が満ちた時だけ評価 --- let cnt = (flow.get("hopCount") || 0) + 1; flow.set("hopCount", cnt); if (buf.length < WIN || cnt < HOP) return null; flow.set("hopCount", 0); // --- 特徴量(加速度の標準偏差 + 角速度平均) --- const accArr = buf.map(b => b.accMag); const mean = accArr.reduce((a, b) => a + b, 0) / accArr.length; const variance = accArr.reduce((a, b) => a + (b - mean) ** 2, 0) / accArr.length; const accStd = Math.sqrt(variance); const score = accStd; flow.set("score", score); // --- ヒステリシス + 最小保持で状態判定 --- let st = flow.get("state") ?? 0; // 0=STILL, 1=ACTIVE let cand = flow.get("cand") ?? 0; let hold = flow.get("hold") ?? 0; let target = (st === 0) ? (score > TH_HIGH ? 1 : 0) : (score < TH_LOW ? 0 : 1); if (target === cand) hold++; else { cand = target; hold = 1; } let event = null; if (cand !== st && hold >= MIN_HOLD) { const label = (cand === 1) ? "STILL->ACTIVE" : "ACTIVE->STILL"; st = cand; event = { payload: { label }, topic: "motion/event" }; } flow.set("state", st); flow.set("cand", cand); flow.set("hold", hold); return event;Notification from AI Agent
By specifying the Discord channel ID in SKILL and instructing the notification method, users will be notified automatically when changes in activity are detected, without requiring any user inquiries.
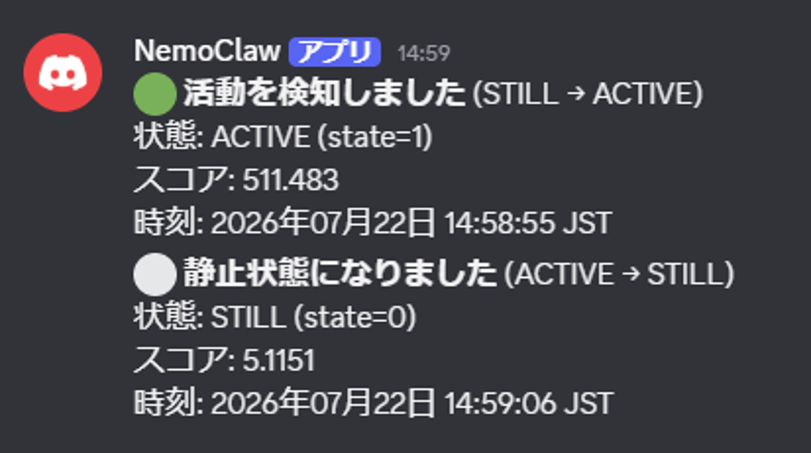
Inquiry
In Episode 4, we explained how to use an acceleration sensor (IMU) to detect changes in activity and notify an AI agent in real time.
In Episode 5, we will review the content of the series so far and discuss future challenges in utilizing IoT sensor data with NemoClaw.